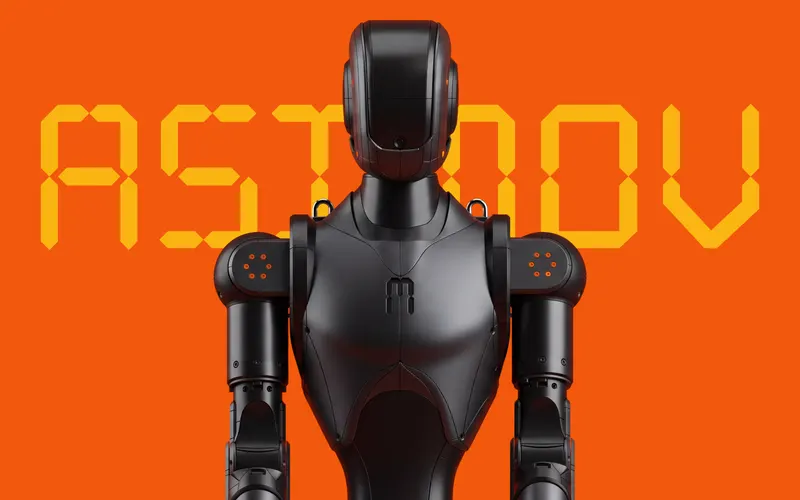
Asimov 1: Advanced Humanoid Engineering
Take an open-source humanoid from CAD to a walking policy. Asimov 1 by Menlo Research is fully published: the mechanical design, the PCBs, the harness, the simulation model and the reinforcement-learning recipe that taught it to walk. This course goes through all of it, deeply. You'll learn how its 165 parts are machined, bent, printed or bought; how its actuators are sized; how its four circuit boards work, reverse-engineered from their own design files; how the 491 Wh battery is protected; and how to source, build and commission the robot. Then the software and the learning: the control loop, Menlo's PPO + AMP training recipe term by term, and the **Training Bay**, where Menlo's real trained policy walks Asimov in full physics in your browser, and where you can run and grade your own. Wire and repair the harness in the STEM Engine, train and upload a policy, and walk the 3D school as your own customised Asimov. **Free with Premium:** this course is never sold on its own. It is built on an open-source robot, so it comes free with Premium, with the Training Bay and an Asimov Hub avatar. Asimov 1 by Menlo Research is licensed CERN-OHL-S-2.0; Menlo's policy and training code are BSD-3-Clause.
71 lessons · Free with Premium
What you will learn
- 1. Module 1: The engineering map
- How Asimov 1 is put together Free10 min
- Open hardware: what the licences ask of you8 min
- Video: We're open-sourcing Asimov v1, a humanoid robot2 min
- Lab: The system in 3D8 min
- Quiz: The engineering map6 min
- 2. Module 2: Mechanical design and fabrication
- Materials and processes10 min
- Subassemblies and part numbers8 min
- Video: How we built humanoid robot legs13 min
- The parallel RSU ankle and flat feet8 min
- Lab: Legs, ankles and limits10 min
- Lab: Fit an actuator6 min
- Quiz: Mechanical design8 min
- 3. Module 3: Actuator engineering
- Sizing an actuator12 min
- The gains and limits a policy is trained with10 min
- Lab: Find every family8 min
- Lab: An A4315 up close6 min
- Quiz: Actuator engineering8 min
- 4. Module 4: PCB design and reverse engineering
- Reading the board sources9 min
- Lab: Reverse-engineer the Motion Control Board10 min
- Inside the Motion Control Board10 min
- Lab: Reverse-engineer the PDB and head board10 min
- Lab: The head board's power and audio8 min
- Making a board: from KiCad to a fab house9 min
- Video: Designing a Compute Board for a Humanoid Robot2 min
- Quiz: PCBs and reverse engineering8 min
- 5. Module 5: Power system design
- Designing the pack10 min
- Protection, the BMS and charging9 min
- Lab: The pack, up close8 min
- Lab: Where the power goes8 min
- Quiz: Power system design8 min
- 6. Module 6: Harness engineering
- The cable list10 min
- Making and checking cables9 min
- Lab: Trace the right leg and the neck8 min
- Quiz: Harness engineering8 min
- 7. Module 7: Sourcing and building
- Buying or making every part10 min
- Video: How to Build Asimov v1: Assembly Guide30 min
- Video: Inside Asimov 1 Production Prep3 min
- Video: What changed on Asimov 1 before shipping5 min
- Lab: Plan the build8 min
- Quiz: Sourcing and building8 min
- 8. Module 8: The software stack and bring-up
- Two computers, one release10 min
- IDs, liveness and zeros10 min
- Lab: Commission the robot8 min
- Video: How to stand Asimov 1 up3 min
- Quiz: Software and bring-up8 min
- 9. Module 9: Kinematics and the simulation model
- URDF and MJCF10 min
- Forward kinematics and mass9 min
- Lab: The whole body, joint by joint10 min
- Quiz: Kinematics and the model7 min
- 10. Module 10: Control in simulation
- The control loop10 min
- Lab: Walk it10 min
- Lab: Break the controller10 min
- Quiz: Control in simulation7 min
- 11. Module 11: Training a walking policy
- Reinforcement learning for walking11 min
- What the robot is rewarded for11 min
- Adversarial motion priors9 min
- Domain randomisation and commands10 min
- Training it yourself10 min
- Video: Open-sourcing Asimov 1: Locomotion Policy & Training Code3 min
- Video: Asimov is now zero-shot sim2real for locomotion1 min
- Quiz: Training a walking policy10 min
- 12. Module 12: Training Bay challenges
- Challenge: The slippery floor10 min
- Challenge: Walk on the Moon10 min
- Challenge: Domain randomisation10 min
- The evaluation course8 min
- Quiz: Training Bay challenges6 min
- 13. Module 13: Customise your Asimov
- Finishes and your Hub avatar8 min
- Lab: Design your Asimov10 min
- 14. Module 14: Capstone
- Your capstone8 min
- Capstone lab: Find the faults8 min
- Final exam12 min