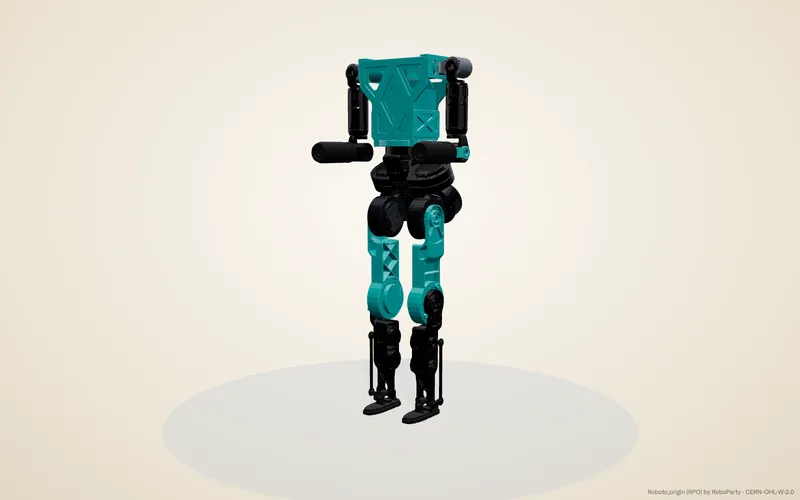
Open-Source Humanoid: Build, Wire and Walk a Robot
A complete, hands-on look inside a real open-source humanoid. Every part of this robot is published: its mechanical design, its circuit board, its wiring, and the trained AI policies that make it walk. This course takes you through all of it, built on RoboParty's open Roboto_origin design. You take the robot apart in 3D, joint by joint and part by part: its 23 joints, the two kinds of Damiao motors that drive them, the main board that powers them and talks to them over four CAN buses, the battery, the E-stop and the computer. You learn how it is assembled, step by step, and you wire its harness by hand in the STEM Engine, graded against the published wiring guide. Then you make it move. You play the motions its makers recorded, and you run their own trained policies in real physics in your browser: walk it, steer it, push it, and watch it dance and get up off the floor. **Free with Premium:** this course is never sold on its own. It is built on an open-source robot, so it comes free with Premium: every Premium member can take it. Roboto_origin is RoboParty's design, published under CERN-OHL-W-2.0 (hardware) and GPL-3.0 (software). This course is Cognita's own and is not affiliated with or endorsed by RoboParty. The real robot is not for under-18s: this course is taught entirely in simulation.
42 lessons · Free with Premium
What you will learn
- 1. Module 1: Meet the robot
- An open humanoid Free10 min
- Lab: The parts of the body8 min
- 23 joints, joint by joint12 min
- Open, but with rules10 min
- Quiz: Meet the robot6 min
- 2. Module 2: How it moves
- Lab: Bend the joints10 min
- Axes and limits: reading the robot's model12 min
- The ankle: two motors, one linkage10 min
- Lab: Poses and the whole body10 min
- Quiz: How it moves6 min
- 3. Module 3: Actuators
- Two motors for 23 joints12 min
- Lab: Find the motors8 min
- PD control: holding a joint where it's told12 min
- Quiz: Actuators6 min
- 4. Module 4: Electronics
- The main board: three jobs on one board12 min
- Lab: Read the board10 min
- The 48 V battery and its rules10 min
- The E-stop and the main switch10 min
- Lab: Find the electronics10 min
- Quiz: Electronics6 min
- 5. Module 5: CAN and the harness
- One cable, many motors: the CAN bus10 min
- Lab: The four buses8 min
- Reading the wiring guide12 min
- When the documents disagree: the torso cable8 min
- Quiz: CAN and the harness6 min
- 6. Module 6: Assembly
- The workbench and its rules10 min
- Building the legs12 min
- Hips, waist and arms12 min
- Lab: The build order10 min
- Lab: Zero every joint12 min
- Quiz: Assembly6 min
- 7. Module 7: Motion and policies
- Lab: Recorded motions10 min
- What a policy sees12 min
- Lab: Walk it12 min
- Lab: Push it8 min
- Lab: Get up and dance12 min
- Quiz: Motion and policies6 min
- 8. Module 8: Bring-up and safety
- Before the power goes on12 min
- Lab: The first stand12 min
- Stopping and fault finding12 min
- Lab: When things go wrong10 min
- Final quiz: Bring-up and safety8 min